Rotary / Angular Time Grating Encoder HTRA3-0035B
Min. Order (MOQ)
1
Lead Time
2 Weeks
Ref. Price
Latest Price
Product Overview:
The Rotary & Angular Time Grating Encoder delivers high-resolution, high-accuracy, and high-repeatability absolute position measurement.
Product Description
The Rotary & Angular Time Grating Encoder delivers high-resolution, high-accuracy, and high-repeatability absolute position measurement. Its robust design ensures shock and vibration resistance, oil resistance, and easy installation, making it ideal for precision devices, motion systems, and industrial automation components. This compact, reliable encoder is perfect for applications requiring fast and precise angular or rotary position detection.
Feature:
1. High-Precision Absolute Measurement
The time grating encoder generates a high-quality time-varying magnetic field that accurately reflects spatial position. By precisely identifying and decoding the spatiotemporal features, it achieves high-accuracy displacement measurement.
· Angular Accuracy: ±40″, ±30″, ±20″, ±10″ (without housing); ±10″, ±5″, ±2″, ±1″ (with housing)
2. High-Speed Operation
Thanks to high subdivision capability, the encoder delivers precise measurement at high speeds, making it ideal for fast-moving systems.
· Angular Speed: up to 7000 rpm (at 223/turn resolution)
3. Ultra-High Resolution
Using high-frequency time-varying magnetic fields as the sensing medium provides strong EMI resistance and high signal-to-noise ratio, enabling fine subdivisions and extremely precise displacement detection.
· Angular Resolution: 21/turn (0.0027466°), 221/turn (0.000172°), 223/turn (0.000043°)
4. Fast Response Time
The encoder offers ultra-fast signal response, with measurement signals reacting within hundreds of nanoseconds and position calculations typically completed in just a few microseconds.
· Linear/Angular Response: 5–10 μs
Highlights:
· High-Precision Time Grating Encoder – Accurate angular and displacement measurement
· High-Speed Performance – Supports up to 7000 rpm
· Ultra-High Resolution – Accuracy up to 0.000043° per turn
· Fast Response & EMI Resistant – Stable signals, measurement in 5–10 μs
· Durable & Easy Installation – Shock, vibration, and oil resistant; compact design
Application:
Time grating encoders provide high resolution, high accuracy, high repeatability, and fast-response absolute position measurement, with compact structure, oil- and dust-resistance, shock- and vibration-proof design, and easy installation. They are widely used in various industries, offering precise real-time position feedback for direct-drive and linear motors, CNC machine tool axes and accessories, automation equipment platforms and actuators, laser processing devices, testing and calibration instruments, as well as robotic joints and manipulators.
Specification
| Specifications | HTRA3-0035B-19-10 |
| Measuring Range | (Single-turn Absolute)0~360° |
| Resolution Ratio | 19bit |
| Accuracy | ±60” |
| Repeatability | ±10” |
| Rotational Speed | ≤7000rpm |
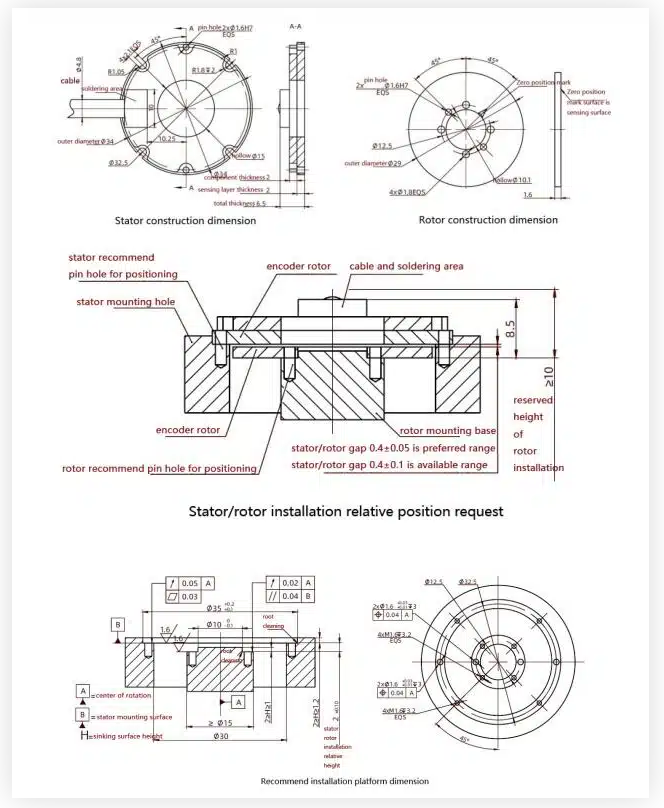
| Rotor(Outer Diameter/Inner Diameter/Thickness) | 30mm/10mm/1.6mm |
| Stator(Outer Diameter/Inner Diameter/Thickness) | 35mm/15mm/6.5mm |
| Stator-Rotor Clearance | 0.4mm±0.1mm |
| Radial Installation Tolerance | ≤0.05mm |
| Operating Voltage | 5V DC±10% |
| Operating Current | ≤200mA |
| Data Format | Natural Binary |
| Rotation Direction | (Default) Viewed from the rotor rear side, clockwise rotation increases the angular data. |
| Communication Type | BISS-C/SSI/UART |
| Communication Speed | BISS-C/SS:(Synchronous Clock) 100K~2.5M UART:9.6K~2.5M |
| Communication Interface | RS422/RS485/ABZ |
| Cable Exit Direction | Radial (customizable upon request) |
| Cable Length | 300mm |
| Operating Temperature | -10~70℃ |
| Operating Humidity | 0~95% |
| Ingress Protection (IP) Rating | IP65 |
Installation dimension